ORB-SLAM using Multiple Cameras
In this project we made a Visual Simultaneous Localization and Mapping (VSLAM) system which integrates measurements from multiple cameras to achieve robust pose tracking and mapping.
Abstract : Most of the autonomous systems such as self- driving vehicles, autonomous aerial systems have multiple cameras but typically use a single camera for SLAM. In this project, we propose a different approach, where we present a Visual Simultaneous Localization and Mapping (VSLAM) system which integrates measurements from multiple cameras to achieve robust pose tracking and mapping for these autonomous systems in unknown complex environments. The well- known feature based ORB SLAM system has been extended to work with three cameras in the final implementation. The theory behind this system can easily be extended to multiple camera configurations. We have implemented this and shown experimental results on custom, KITTI, and the Argoverse datasets.
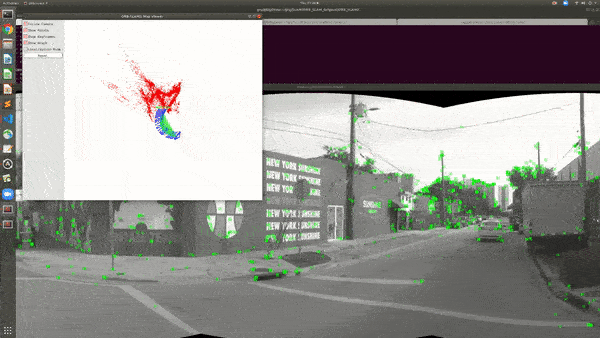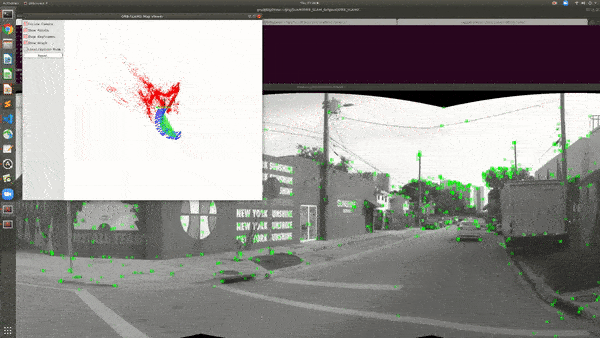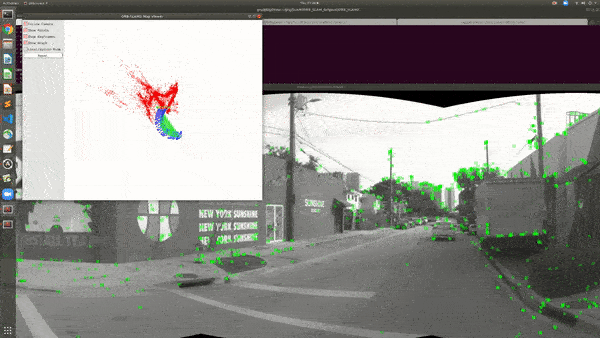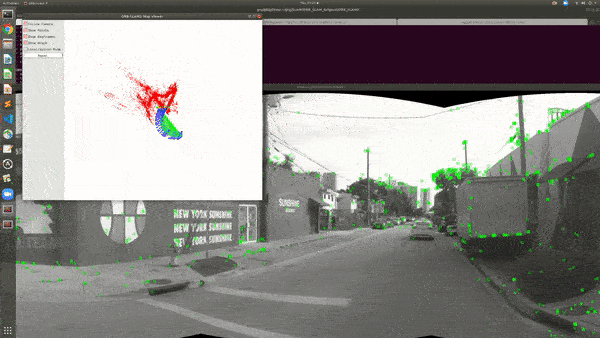
A demo video of the project can be found by clicking on the image below
For detailed information, please refer the white paper.