3D Dense Reconstruction Using ICP and Point-based Fusion
In this project we implemented a 3D dense mapping system that reconstructs a 3D dense model with the given RGB-D image sequences.
In this project we implemented a 3D dense mapping system that reconstructs a 3D dense model of a static indoor environment with given RGB-D image sequences. The system follows the tracking and mapping framework proposed in 1, which is commonly used in many state-of-the-art visual tracking and mapping systems. In this framework, mapping relies on the pose estimation from tracking to update the global model, and tracking uses the refined global model from mapping as reference.
The visual tracking part of the system, which is also known as localization or visual odometry (VO), is solved using point-to-plane iterative closest point (ICP) 2. The mapping part is done using point-based fusion 1. However, unlike in 1, we did not consider the estimation of dynamic objects in this project since the input data are from a static environment.
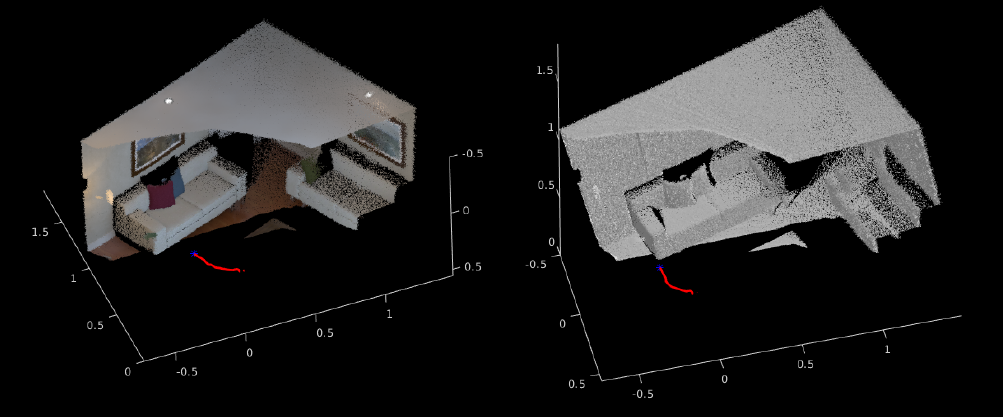
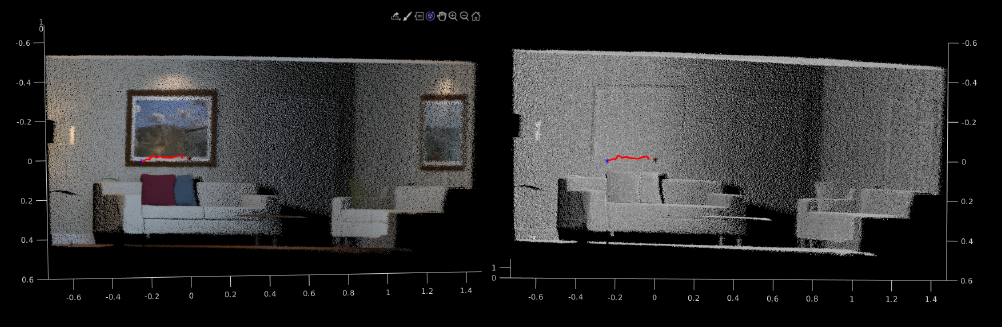
The output of the system for a squence of RGBD is shown below: