Particle Filter
In this assignment, our task was to implement the popular Particle Filter technique for localising a robot given its sensor data and a map.
Particle filters are a type of state estimators. In this project we use the principle of particle filters to perform Monte Carlo Localization.
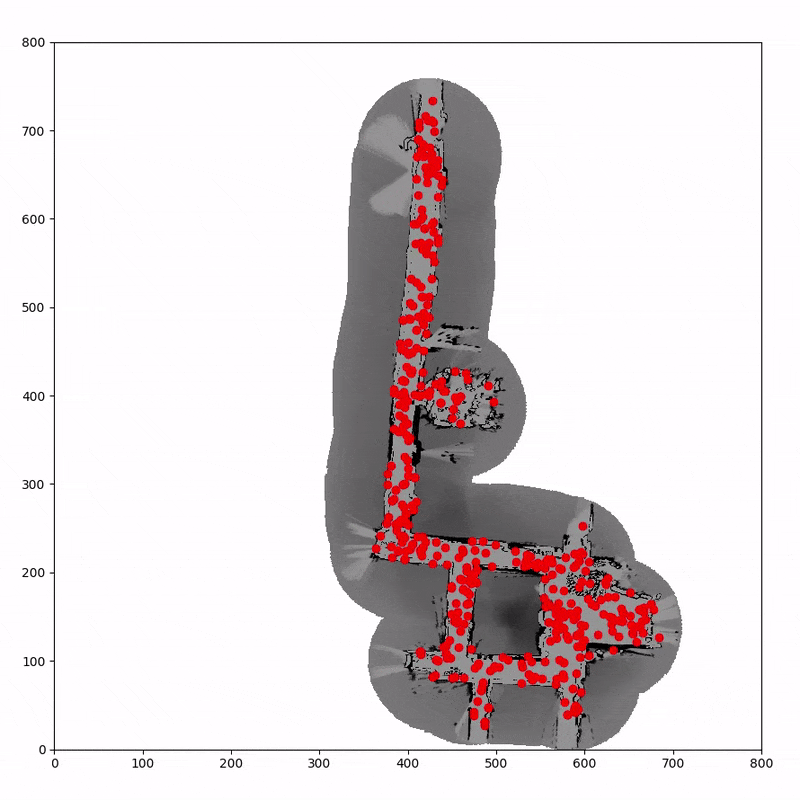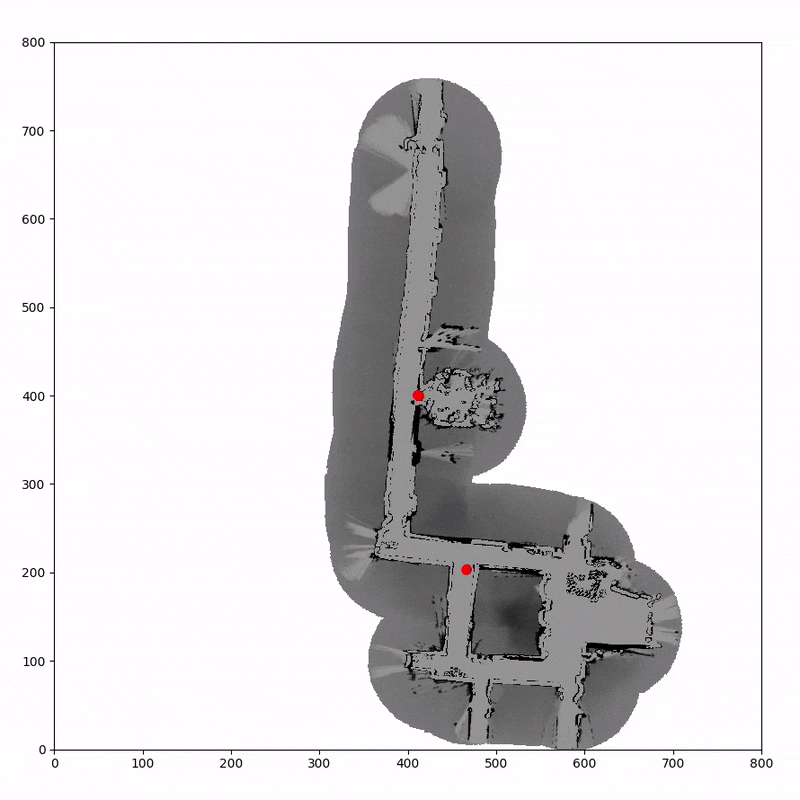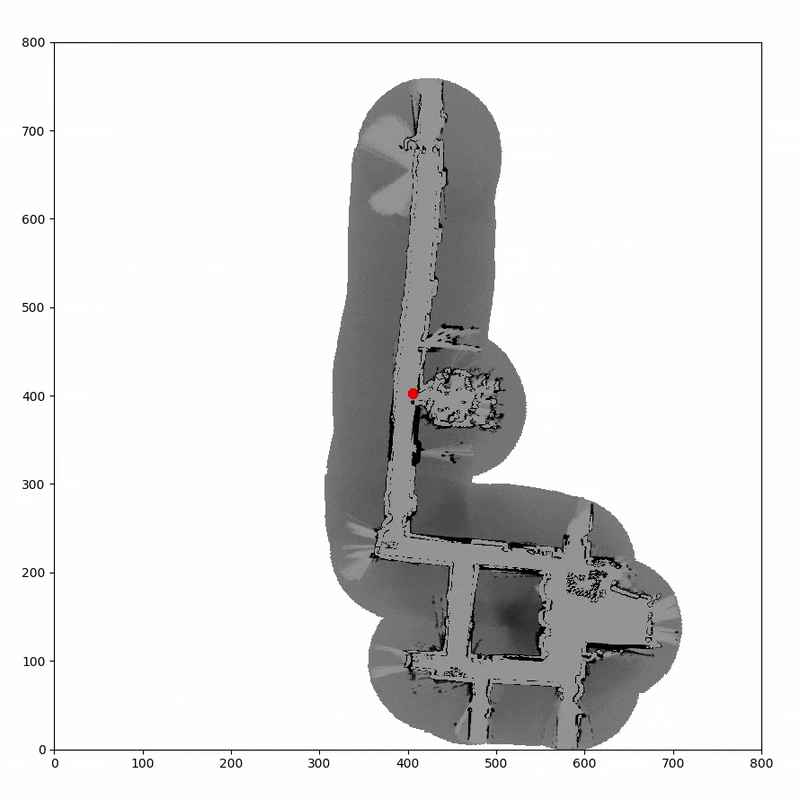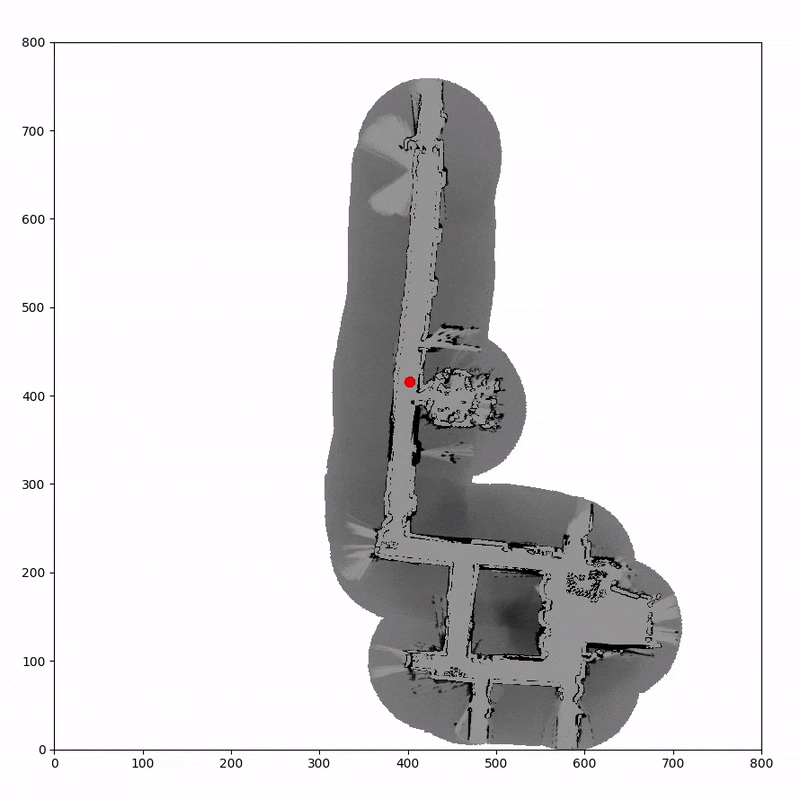
We implemented the motion model, the sensor model including ray tracing and also the resampling techqnique for accurately localising the robot across map. The result of running the algorithm can be seen in the gif shown below. Please click on the gif to watch the entire video.